К содержимому
learnspaceYOUR NEXT CHAPTER
ПРОСТРАНСТВО ОБУЧЕНИЯ
ГлавнаяКаталог курсовМоё обучениеCoursera

Знания без границ

Учитесь у лучших университетов и компаний мира.

Открыть Coursera
Интеграция
Пространство университета
Моё пространствоСтраница курса
↵
ЯЛичный кабинетСтудент
© 2026 LearnSpaceКаждый день — возможность узнать больше.Помощь
Robotics: Mobility · LearnSpace
Назад в каталог
courseraИнженерия

Robotics: Mobility

Курс от University of Pennsylvania
Уровень не указан≈ 20 чАнглийский
О курсеНавыкиПрограммаПреподаватели

О курсе

How can robots use their motors and sensors to move around in an unstructured environment? You will understand how to design robot bodies and behaviors that recruit limbs and more general appendages to apply physical forces that confer reliable mobility in a complex and dynamic world. We develop an approach to composing simple dynamical abstractions that partially automate the generation of complicated sensorimotor programs. Specific topics that will be covered include: mobility in animals and robots, kinematics and dynamics of legged machines, and design of dynamical behavior via energy landscapes.

Навыки, которые вы освоите

RoboticsMechanicsControl SystemsMathematical ModelingMechanical DesignTorque (Physics)CoordinationDifferential EquationsMatlabBiologyEngineeringAutomation EngineeringMachine ControlsApplied MathematicsMechanical EngineeringPhysics

Программа курса

4 модулей · 66 учебных материалов

01Introduction: Motivation and Background18 материалов

0.0 What you will learn in this course

Learning Style Preference SurveyЗадание0.0.0 What you will learn in this courseВидео

1.0 What you will learn this week

1.0.0 What you will learn this weekВидео

1.1 Motivation

1.1.1 Why and how do animals move?Видео

Учитесь у экспертов

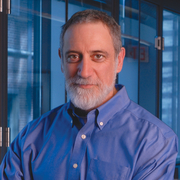
Daniel E. Koditschek

Professor of Electrical and Systems Engineering

Robotics: Mobility
В каталоге вашей программы

Инвестируйте в себя

Новые знания — в удобное для вас время.

Начать на Coursera

Обучение откроется на Coursera
в новой вкладке

Обучение на Coursera

≈ 20 ч

4 модулей

Язык: Английский

Субтитры: Арабский, Французский, Бенгальский, Украинский, Китайский (Китай), Греческий, Итальянский, Бразильский португальский, Нидерландский, Корейский, Ория, Немецкий, Пушту, Урду, Русский, Тайский, Индонезийский, Шведский, Турецкий, Азербайджанский, Испанский, Дари, Хинди, Японский, Казахский, Венгерский, Польский

Часть программы вашего университета
1.1.1 Why and how do animals moveЗадание
1.1.2 BioinspirationВидео
1.1.2 BioinspirationЗадание
1.1.3 Legged Mobility: dynamic motion and the management of energyВидео
1.1.3 Legged Mobility: dynamic motion and the management of energyЗадание
Setting up your MATLAB environmentЧтение
MATLAB Tutorial I - Getting Started with MATLABЧтение
MATLAB Tutorial II - ProgrammingЧтение

1.2 Mechanical Dynamical Systems

1.2.1 Review LTI Mechanical Dynamical SystemsВидео1.2.2 Introduce Nonlinear Mechanical Dynamical Systems: the dissipative pendulum in gravityВидео1.2.2 Nonlinear mechanical systemsЗадание1.2.3 Linearization & Normal FormsВидео1.2.3 LinearizationsЗаданиеOpt-in to Penn Engineering Online CommunicationsЧтение
02Behavioral (Templates) & Physical (Bodies)15 материалов

2.0 What you will learn this week

2.0.0 What you will learn this weekВидео

2.1 Templates

2.1.1 Walking like a rimless wheelВидео2.1.1 Walking like a rimless wheelЗадание2.1.2 Running like a spring-loaded pendulumВидео2.1.2 Running like a spring-loaded pendulumЗадание2.1.3 Controlling the spring-loaded inverted pendulumВидео2.1.3 Controlling the spring-loaded inverted pendulumЗадание

2.2 Components: Materials, Structures

2.2.1 Metrics and Scaling: mass, length, strengthВидео2.2.1 Metrics and Scaling: mass, length, strengthЗадание2.2.2 Materials, manufacturing, and assemblyВидео2.2.2 Materials, manufacturing, and assemblyЗадание2.2.3 Design: figures of merit, robustnessВидео2.2.3 Design: figures of merit, robustnessЗадание

2.3 Power, Information

2.3.1 Actuator technologiesВидео2.3.1 Actuator technologiesЗадание
03Anchors: Embodied Behaviors12 материалов

3.0 What you will learn this week

3.0.0 What you will learn this weekВидео

3.1 Review: Core, Limbs & Appendages in Motion and at Work

3.1.1 Review of kinematicsВидео3.1.1 Review of kinematics (MATLAB)Задание3.1.2 Introduction to dynamics and controlВидео3.1.2 Introduction to dynamics and controlЗадание

3.2 Design: by Animals; by Engineers

3.2.1 Sprawled posture runnersВидео3.2.1 Sprawled posture runnersЗадание3.2.2 QuadrupedsВидео3.2.2 QuadrupedsЗадание3.2.3 BipedsВидео3.2.3 BipedsЗаданиеSimply stabilized SLIP (MATLAB)Задание
04Composition (Programming Work)21 материалов

4.0 What you will learn this week

4.0.0 What you will learn this weekВидеоOpt-in to Penn Engineering Online CommunicationsЧтение

4.1 Dynamical Composition

4.1.1 Sequential and Parallel CompositionВидео4.1.1 Sequential and Parallel CompositionЗадание

4.2 Parallel Composition

4.2.1 Why is parallel hard?Видео4.2.1 Why is parallel hard?Задание(SUPPLEMENTARY) 4.2.2 SLIP as a parallel vertical hopper and rimless wheelВидео(SUPPLEMENTARY) 4.2.2 SLIP as a parallel compositionЗадание4.2.3a RHex: A Simple & Highly Mobile Biologically Inspired Hexapod RunnerВидео4.2.3a RHexЗадание(SUPPLEMENTARY) 4.2.3b Clocked RHex gaitsВидео(SUPPLEMENTARY) 4.2.3b Clocked RHex gaitsЗадание

4.3 Horizons of Research

4.3.1 Compositions of vertical hoppersВидео4.3.1 Compositions of vertical hoppersЗаданиеMATLAB: composition of vertical hoppersЗадание4.3.2 Same composition, different bodiesВидео4.3.2 Same composition, different bodiesЗадание4.3.3 Same body, different compositionsВидео
4.3.3 Same body, different compositionsЗадание
4.3.4 Transitions: RHex, Jerboa, and Minitaur leapingВидео
4.3.4 TransitionsЗадание